









출고예상일 안내
주문하신 상품이 한국에서 현지 배송을 위한 출고단계가 이루어질 것으로 예상되는 날짜입니다. 상품을 준비하는 과정에서 내부적인 사정으로 인해 출고예상일에 다소 오차가 생길 수 있습니다.
여러 상품(예약상품포함)을 함께 주문하신 경우 출고예상일이 가장 늦은 날짜에 맞춰 함께 배송됩니다.


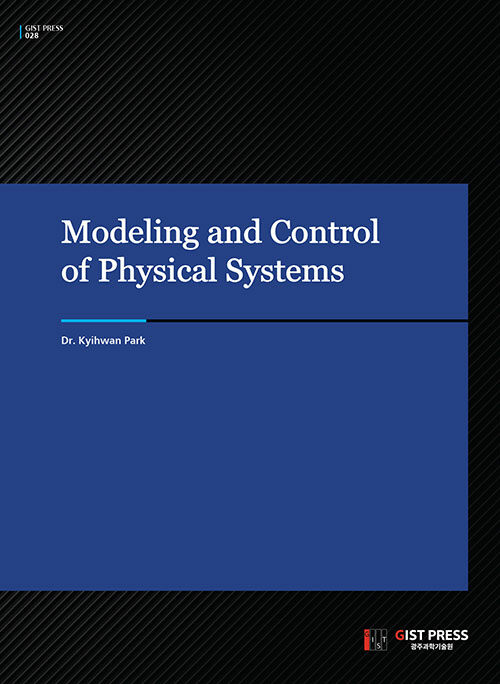
Modeling and Control of Physical Systems - GIST PRESS 28
DR KYIHWAN PARK 저 | GIST PRESS(광주과학기술원) | 2023년 10월





ISBN : 9791190961189 / 280쪽 / 532g / 188 x 257 (㎜)
이 상품에 궁금하신점이 있으세요? 1:1상담문의



아래의 도서와 구매하시면 이 도서들의 적립금을 즉시적용해 드립니다.
-
마창석
-
구오제드, 송이핑, 조신
-
조성호
-
천근아, 박정훈, 장지흠, 진재연, 이정한, 민윤기
- 22,500
- 26,100
- 29,700
- 22,500


출판사 리뷰

-
- 저자 : DR KYIHWAN PARK

CHAPTER 01 Conventional modeling methods
1.1 Modeling process
1.2 Input sources in mechanical systems
1.3 Constitutive relations
1.4 Modeling of mechanical systems
1.5 Load effect
1.6 Passive system; non-isolated system
CHAPTER 02 Bond graph modeling for mechanical system
2.1 Power flow in physical systems
2.2 Bond graph modeling in mechanical systems
2.3 Causality
2.4 State equations
CHAPTER 03 Bond graph modeling for electrical systems
3.1 Constitutive relations
3.2 Bond graph model of electric circuits
3.3 Voltage source and current source in electric circuits
3.4 State equations of electrical circuits
3.5 Causality problem in an electronic circuit
3.6 Bond graph for hydraulic systems
3.7 Pneumatic systems
CHAPTER 04 Response analysis
4.1 Time response analysis for a first order system
4.2 Time response analysis using the Laplace transformation method
4.3 Time response analysis of a second-order system
4.4 Frequency response analysis
4.5 Steady state response analysis for various time inputs
4.6 Transient response based on frequency response analysis
4.7 Frequency response of a high-order system
CHAPTER 05 Electromechanical systems
5.1 Magnetic field system
5.2 Analysis of the magnetic field system
5.3 Magnetic circuit theory
5.4 Magnetic field analysis of a permanent magnet
5.5 Magnetic field in a moving media
5.6 Bond graph representation of an electromechanical system
5.7 Various electromechanical systems
5.8 Appendix
CHAPTER 06 Control
6.1 Why is a feedback loop needed?
6.2 Feed-forward transfer function
6.3 Analysis of the closed loop system
6.4 Analysis of an open loop system
6.5 Compensator design
6.6 Design of control components for good command following
6.7 Stability of an electronic system
6.8 Sampling effect on control
6.9 Control applications
6.10 Loop shaping controller
CHAPTER 07 Controller implementation using operational amplifiers
7.1 Load-effect-free operational ampliflier
7.2 Amplifiers
7.3 Various controller using operational amplifiers
7.4 Electronic circuits for a plant realization and feedback control
7.5 Experiment of feedback control
CHAPTER 08 Signal processing for sensing systems
8.1 Sensor specifications
8.2 Components of optical sensors
8.3 Amplitude modulation
8.4 Phase and frequency modulation

